What Is the Best FANUC Palletizing Robot in 2026?
Choosing the best FANUC palletizing robot in 2026 starts with the load, not the brochure. A 12-kilogram carton and a heavy, shifting bag demand different reach, payload, tooling, and motion. So does a low ceiling or a narrow aisle. Small details matter.
The market is moving quickly. The International Federation of Robotics reported 541,302 industrial robot installations worldwide in 2023, with 4,281,585 robots in operation. IFR President Marina Bill said, “The new World Robotics report shows an all-time high in the number of industrial robots in operation worldwide.” These figures describe industrial robotics broadly, not palletizers alone, but they show why buyers are comparing automation options carefully.
This guide evaluates FANUC models through practical questions: Can the arm reach every pallet corner? Will the gripper hold slippery bags through a full shift? Does the cell fit beside conveyors, guards, and forklift lanes? Fast cycle times look impressive. Yet a robot that struggles with a changing case pattern can create extra work. There is no universal winner, and model specifications should be checked against FANUC’s current documentation and the actual application.
We will compare payload, reach, speed, footprint, and integration needs, then explain which use cases favor each option. The best choice is the one that stacks reliably on your floor—not merely the one with the largest numbers. A little skepticism helps.
FANUC Palletizing Robots Explained: Payload, Reach, and 4-Axis Design
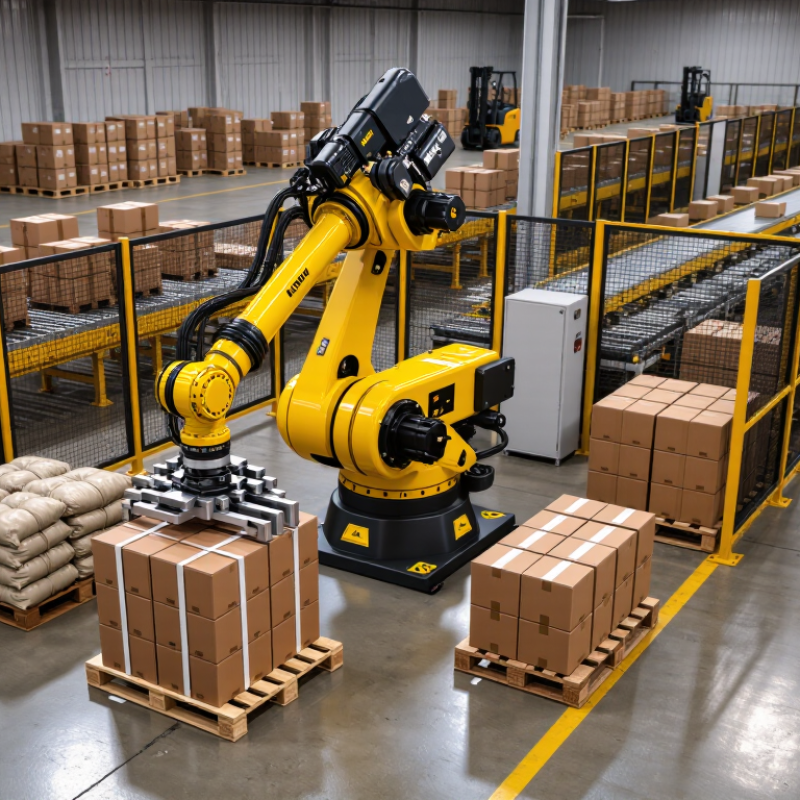
A palletizing robot is chosen by payload, reach, cycle time, and floor layout—not by payload alone.
Add the gripper’s weight to the heaviest case, then leave margin for acceleration and repeated shifts. A 20-kilogram carton with a 6-kilogram end effector already requires more than 20 kilograms of rated capacity. Reach matters just as much. Measure from the robot’s mounting point to the farthest pallet corner, including the conveyor pickup point. A 4-axis design rotates and positions loads efficiently on a flat layer, while using fewer motion axes than many general-purpose arms. It is a focused design. But tight aisle clearance or tall stacks can expose limits that a simple reach number hides.
The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023 in its World Robotics 2024 report. That is useful context, not palletizing-specific evidence; the report does not identify a single best palletizing configuration.
For a real comparison, test the intended box pattern at production speed, with the actual gripper and pallet. Check wrist rotation, cable routing, and access for maintenance. A reach estimate can look precise, yet carton slip or uneven layers may still slow a cell. Pilot results matter. A small trial with mixed case sizes can reveal issues that a clean specification sheet will not.
FANUC M-410iC/185 vs. M-410iC/500: Choosing 185 kg or 500 kg Payload
The M-410iC/185 and M-410iC/500 differ most in payload capacity: 185 kg versus 500 kg. That gap matters when a palletizing cell handles heavy layers, large grippers, or several cartons in one pick. Payload planning must include the tool, cables, and product—not just the item listed on the carton. A gripper can consume a surprising share of the allowance.
For mixed cases or lighter cartons, the 185 kg model may be the more practical fit. It can avoid paying for capacity the line rarely uses. The 500 kg model suits heavier picks, but rated payload alone does not guarantee a fast cycle. Reach, wrist moment, motion speed, and the load’s center of gravity also shape performance. Real cartons rarely behave perfectly. Check the heaviest, widest, and least stable load, then test the proposed pattern at production speed. That is easy to overlook. Confirm available floor space, mounting requirements, and the gripper design before choosing; a larger payload rating can change the cell layout and investment. A little uncertainty remains until the actual load and cycle are tested.
How the M-410iC’s 3,143 mm Reach Shapes Pallet-Cell Layout
A 3,143 mm reach sounds generous, but it does not create a usable 3,143 mm work circle. The figure describes the robot’s rated reach, not the space available after adding a gripper, pallet overhang, guarding, and safe access routes. In a pallet cell, those details decide whether the arm can place cartons cleanly at the far corners. A long carton may clear the robot but still collide with a fence or neighboring load. Small detail. Big consequence.
Plan the cell around the tool center point and the full motion path, not just the robot’s base position. Leave room for the gripper to approach low layers without scraping the pallet, and check whether the arm can reach both pickup and drop-off points without awkward wrist turns. The International Federation of Robotics’ World Robotics 2024 report recorded 541,302 industrial robot installations worldwide in 2023. That scale reflects growing automation, but it does not make every layout efficient. The 2024 MHI Annual Industry Report also found that 55% of respondents were increasing supply-chain technology investment. A reach drawing can look convincing. I would still validate it with a swept-path simulation and a physical carton mock-up; packaging dimensions are often less tidy than the CAD model.
What Is the Best Palletizing Robot in 2026? — How a 3,143 mm Reach Shapes Pallet-Cell Layout
| Planning dimension |
Value or status |
What it means for cell layout |
Planning note |
| Nominal reach |
3,143 mm |
Provides a useful first reference for the robot’s potential working envelope. |
Reach alone does not confirm that every point in the cell is accessible. |
| Metric conversion |
3.143 m |
Makes it easier to compare reach with equipment and aisle dimensions shown in metric drawings. |
Use the same units throughout layout drawings and installation documents. |
| Imperial conversion |
Approximately 10.31 ft |
Offers a convenient reference for teams working with imperial measurements. |
Converted from 3,143 mm; rounded to two decimal places. |
| Pallet positions served |
Depends on the validated work envelope |
A longer reach may help the robot serve multiple positions, depending on their location and orientation. |
Confirm each pick and place point in simulation or with a reach study. |
| End-of-arm tooling |
Application-specific; not defined by reach alone |
Tool length, package size, and approach angle affect clearance and usable access. |
Include the complete tool and load geometry in collision checks. |
| Robot mounting position |
Must be established for the cell design |
The mounting location affects access to conveyors, pallet stations, and service areas. |
Check reach, robot motion, guarding, and maintenance access together. |
| Payload and cycle time |
Not determined by the reach figure |
These factors influence product handling and throughput, but cannot be inferred from reach alone. |
Verify payload, motion limits, and target cycle time for the selected application. |
Layout figures are planning references. Confirm the robot’s complete work envelope, load, tooling, clearances, and safety requirements against the applicable technical documentation before finalizing a pallet cell.
How to Compare Cycle Time, Cases per Hour, and End-of-Arm Tooling
A palletizing robot should be judged by the pallets it can build reliably, not by one impressive cycle-time figure. Compare cycle time using your real case weight, pallet pattern, reach, and approach path. A robot moving empty cartons through a short route may look fast, but production runs include loaded picks, placement, and occasional pauses. Small differences add up.
Cases per hour is the more useful production measure. Track good cases placed over a full shift, including replenishment delays and line stops. For example, a cell rated at 1,000 cases per hour may deliver less when cartons arrive unevenly or pallets need changing. Measure several representative products. One test is not enough.
Tips: Test the end-of-arm tooling with actual cartons, including dusty, soft, or slightly crushed boxes. Check grip consistency, release accuracy, and changeover time. Vacuum tooling may suit flat surfaces; mechanical gripping can help with variable cartons. Confirm the tool handles your heaviest case without slowing the cycle. Then compare hourly output under the same conditions. It is easy to overlook carton variation. I would retest after a format change, even if the first trial looked fine.
Which FANUC Palletizing Robot Fits Your Load, Pallet, and Throughput Targets?
The best palletizing robot is the one that handles your real production pattern, not just the heaviest box on paper. Record each product’s weight, dimensions, and grip points. Then map the pallet’s length, width, height, and permitted overhang. Small details matter. A tall, narrow load may need different reach and stability than a compact case. Check the robot’s rated payload alongside the gripper’s weight, and confirm its working envelope reaches every pallet position without awkward wrist angles.
Tips: Measure cycle time using the full task: pick, travel, place, and return. Include layer changes and pallet exchanges. Ask for a test with your actual cartons; glossy packaging or soft bags can behave differently from rigid boxes. Leave room for guarding and maintenance access.
Throughput targets should reflect sustained operation, not a brief peak. Compare the required cases per hour with the robot’s expected cycle time, then allow for upstream delays and occasional recovery. Also review floor space, conveyor height, and how operators will replenish materials. A smaller payload rating may be sufficient when the gripper is light and the load is compact. Still, margins matter. I would not finalize a selection from a spreadsheet alone; a site trial can reveal reach conflicts and unstable layers that calculations miss.
Choosing a Palletizing Robot in 2026: Match Load, Pallet & Throughput
Common pallet footprints, compared by length and width. Dimensions are in millimeters.
Pallet size is one part of robot selection. Confirm the robot’s reach across the full pallet pattern, payload capacity including the gripper, and the required cycle rate using your actual products and layout.